
点群からマーチングキューブス(Hoppe)で面を作成(PCLライブラリ)†
PCLライブラリを使用して、マーチングキューブス法(Hoppe)で点群から面を作成します。
ここでは、ねこの点群を入力にします。
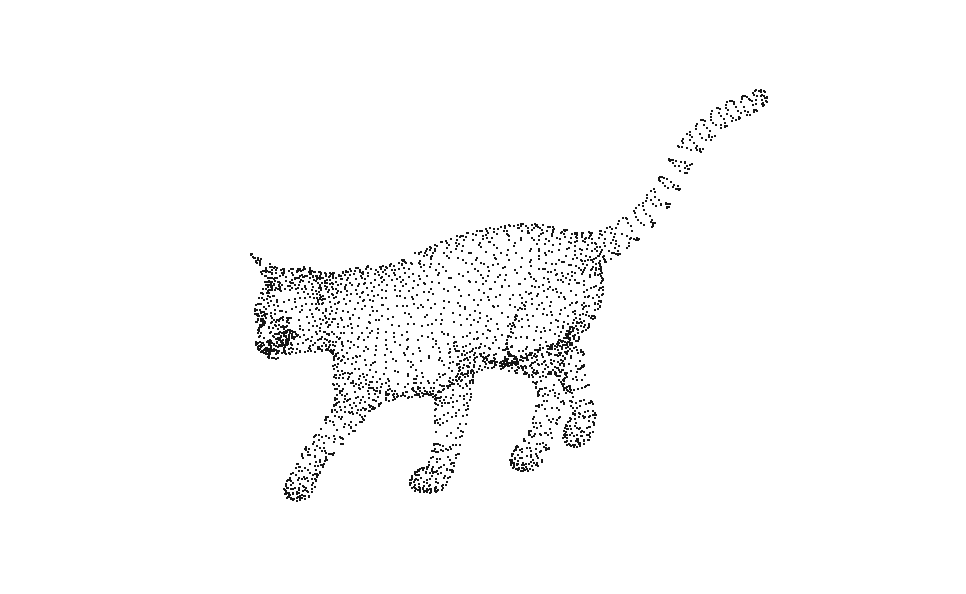
では早速、下のプログラムでマーチングキューブス法で面を作成してみます。
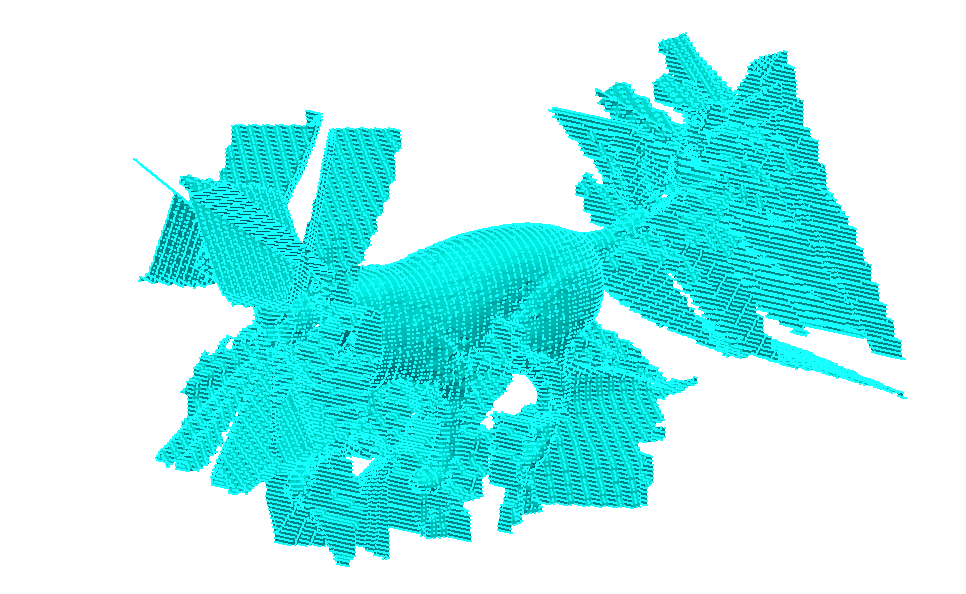
うまくいきません。。ねこの周りに、いらない面が残ってしまいます。0の等値面はどのように定義されているのでしょうか?
pcl_marching_cubes_hoppe.cxx†
#include <pcl/point_types.h>
#include <pcl/io/pcd_io.h>
#include <pcl/io/vtk_io.h>
#include <pcl/features/normal_3d.h>
#include <pcl/surface/marching_cubes_hoppe.h>

int
main (int argc, char** argv)
{
  std::string input_file, output_file;

  if (argc < 3)
  {
    printf ("\nUsage: marching_cubes_hoppe pcd<PointXYZ>-in-file vtk-out-file\n\n");
    exit(0);
  }
  input_file = argv[1];
  output_file = argv[2];

  // Load input file into a PointCloud<T> with an appropriate type
  pcl::PointCloud<pcl::PointXYZ>::Ptr cloud (new pcl::PointCloud<pcl::PointXYZ>);
  pcl::PCLPointCloud2 cloud_blob;
  pcl::io::loadPCDFile (input_file, cloud_blob);
  pcl::fromPCLPointCloud2 (cloud_blob, *cloud);
  //* the data should be available in cloud

  // Normal estimation*
  pcl::NormalEstimation<pcl::PointXYZ, pcl::Normal> n;
  pcl::PointCloud<pcl::Normal>::Ptr normals (new pcl::PointCloud<pcl::Normal>);
  pcl::search::KdTree<pcl::PointXYZ>::Ptr tree (new pcl::search::KdTree<pcl::PointXYZ>);
  tree->setInputCloud (cloud);
  n.setInputCloud (cloud);
  n.setSearchMethod (tree);
  n.setKSearch (20);
  n.compute (*normals);
  //* normals should not contains the point normals + surface curvatures

  // Concatenate the XYZ and normal fields*
  pcl::PointCloud<pcl::PointNormal>::Ptr cloud_with_normals (new pcl::PointCloud<pcl::PointNormal>);
  pcl::concatenateFields (*cloud, *normals, *cloud_with_normals);
  //* cloud_with_normals = cloud + normals

  // Create search tree
  pcl::search::KdTree<pcl::PointNormal>::Ptr tree2 (new pcl::search::KdTree<pcl::PointNormal>);
  tree2->setInputCloud (cloud_with_normals);

  // Initialize objects
  pcl::MarchingCubesHoppe<pcl::PointNormal> mc;
  pcl::PolygonMesh triangles;

  // Set parameters
  mc.setIsoLevel (0.0);
  mc.setGridResolution(100, 100, 100);
  mc.setPercentageExtendGrid(0.3f);

  // Get result
  mc.setInputCloud (cloud_with_normals);
  mc.setSearchMethod (tree2);
  mc.reconstruct (triangles);

  pcl::io::saveVTKFile (output_file, triangles);

  // Finish
  return (0);
}
ダウンロードとビルド†
ソースコードとCMakeLists.txtファイル:
添付ファイル:  pcl_marching_cubes_hoppe.zip 1294件
[詳細]
neko_surface1.png 2006件
[詳細]
neko_cloud_ponits.png 2061件
[詳細]
pcl_marching_cubes_hoppe.zip 1294件
[詳細]
 neko_surface1.png 2006件
[詳細]

 neko_cloud_ponits.png 2061件
[詳細]

Last-modified: 2014-05-23 (金) 19:00:20